Perception Engineer II
MVP Robotics
May 2024 — Present
Vermont, USA
- Designed and implemented a real-time obstacle detection neural network with a novel image encoding method for autonomous mobile robots in multi-terrain, day and night outdoor environments — 92% detection accuracy while reducing training data requirements by 25% versus RGB-based methods.
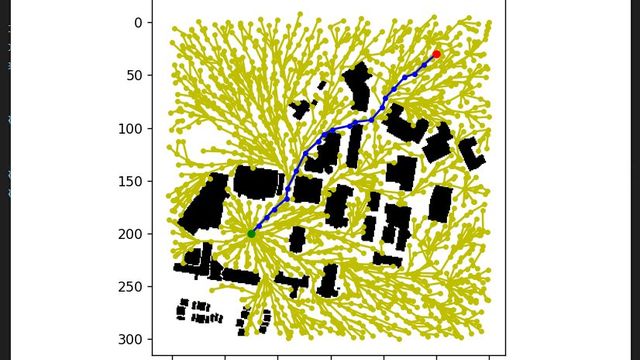
- Developed SLAM and a hybrid Vector Field Histogram (VFH+) path planner for real-time obstacle avoidance running on NVIDIA Jetson AGX Orin.
- Built a human detection and tracking pipeline integrated into the robot's production autonomy kit.
- Developed the autonomy perception stack for SAGE, a modular robot compute platform, supporting LiDAR and camera sensor integration.
- Engineering a GNSS + visual-inertial odometry (VIO) sensor fusion stack to improve real-time positioning accuracy in GPS-denied environments.